About us
In control, we turn algorithms into real autonomy. Our mission is to take an objective and transform it into physical motion. To do so, we combine reinforcement learning, behavior trees and automatic control, each contributing a different capability: learning from experience, structuring decisions, and keeping the vehicle stable and responsive.
The result is a vehicle that navigates, follows routes, stabilizes itself and makes decisions to reach its goal in a safe and efficient manner. Safety and efficiency are not separate goals for us. We design our controllers and planners so that a path is judged not only by whether it arrives, but by how it gets there.
Networks and Telecommunications
We are the architects of our robots' messaging. Everything a vehicle senses, decides and executes travels through the systems we design.
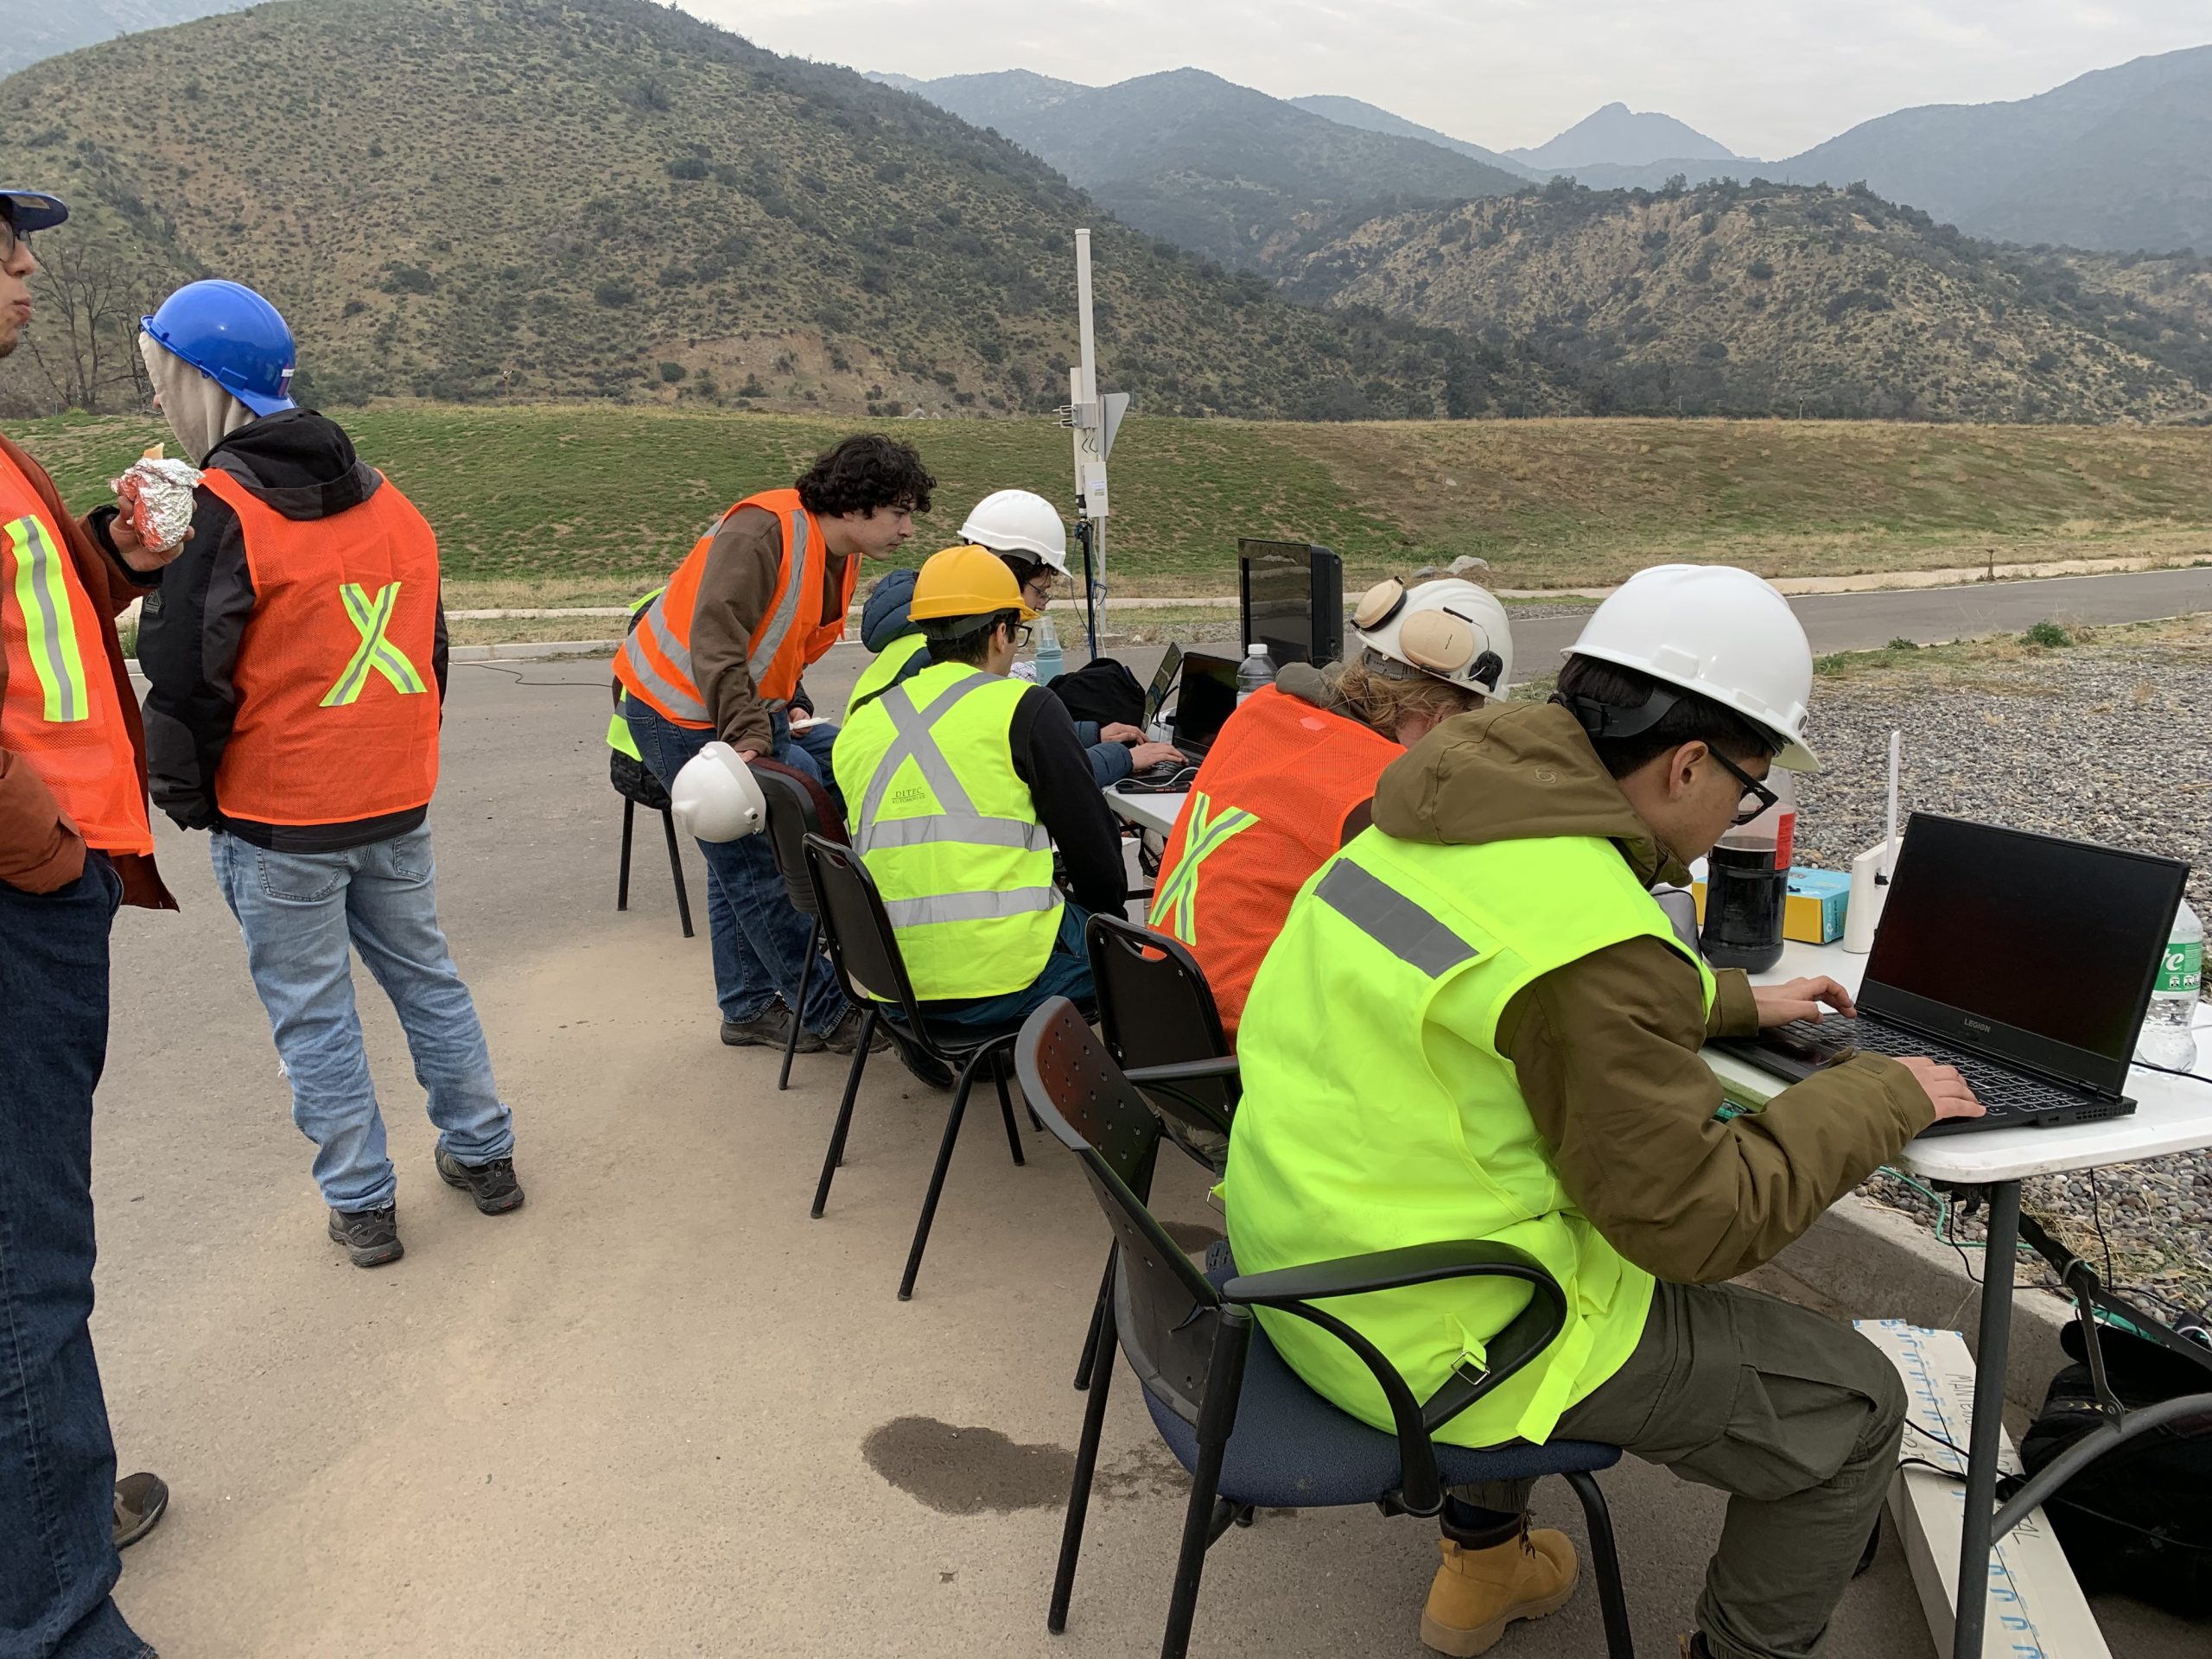
We build fast, efficient network architectures that guarantee effective communication between sensors and actuators. We also develop the code that shares information among our different vehicles and with our ground personnel, and that maintains coordination among the robots during operation. A team of autonomous vehicles is only as strong as its ability to stay connected and act together.
All of this runs on high-grade hardware, which gives us a robust and dependable system.